COMPUTER VISION IN AUTONOMOUS VEHICLES
DOI:
https://doi.org/10.71465/csb128Keywords:
Computer vision, object detection, sensor fusion, self-driving cars, deep learning, real-time processing, LiDAR, transportation safety, Remove object detection machine learning, Autonomous VehiclesAbstract
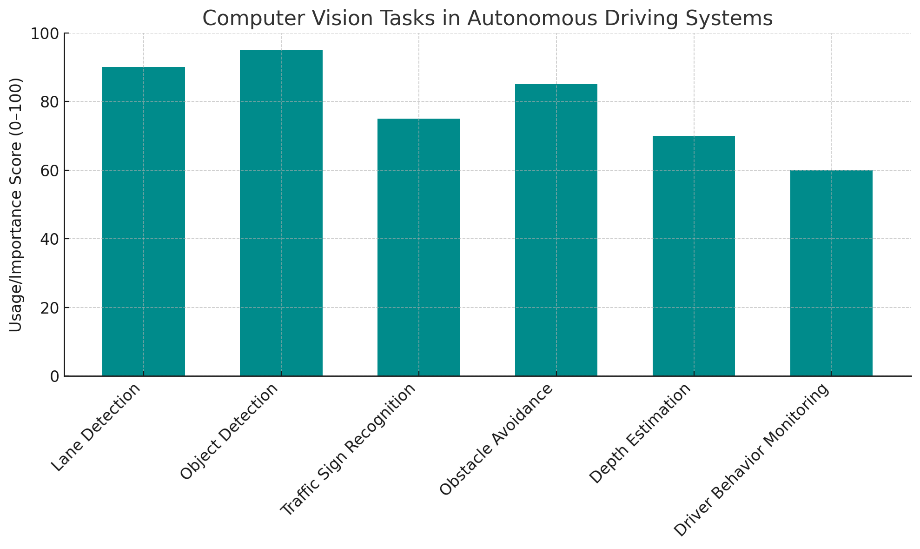
Computer vision is a critical technology in the development of autonomous vehicles, enabling them to interpret and interact with their environment. By processing visual data from cameras and sensors, computer vision systems can detect, recognize, and track objects such as pedestrians, other vehicles, traffic signals, and road conditions. This paper explores the role of computer vision in autonomous driving, examining key techniques, algorithms, and systems that power autonomous vehicles. We delve into challenges such as sensor fusion, real-time processing, object detection, and safety. Furthermore, we discuss the integration of computer vision with other technologies like machine learning, LiDAR, and radar to enhance vehicle autonomy. The paper concludes with an analysis of the future of computer vision in self-driving vehicles and its implications for transportation and society.
Downloads
Published
Issue
Section
License
Copyright (c) 2024 Computer Science Bulletin

This work is licensed under a Creative Commons Attribution 4.0 International License.
All articles published in the Computer Science Bulletin are distributed under an open access license, allowing unrestricted use, distribution, and reproduction in any medium, provided the original work is properly cited. Authors retain copyright and grant the journal the right of first publication. The journal encourages knowledge sharing while maintaining academic integrity and proper attribution.